

X.P.A.R.O
Live your DREAMS parallelly
Connect, program and operate your ROS 2 robot fleet from the browser.
Features
Everything you need to build, run and operate a robot fleet, in one place.
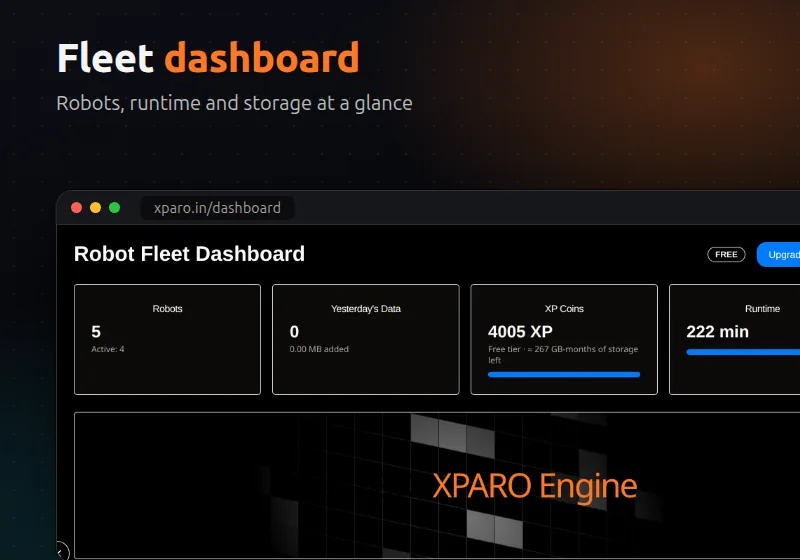
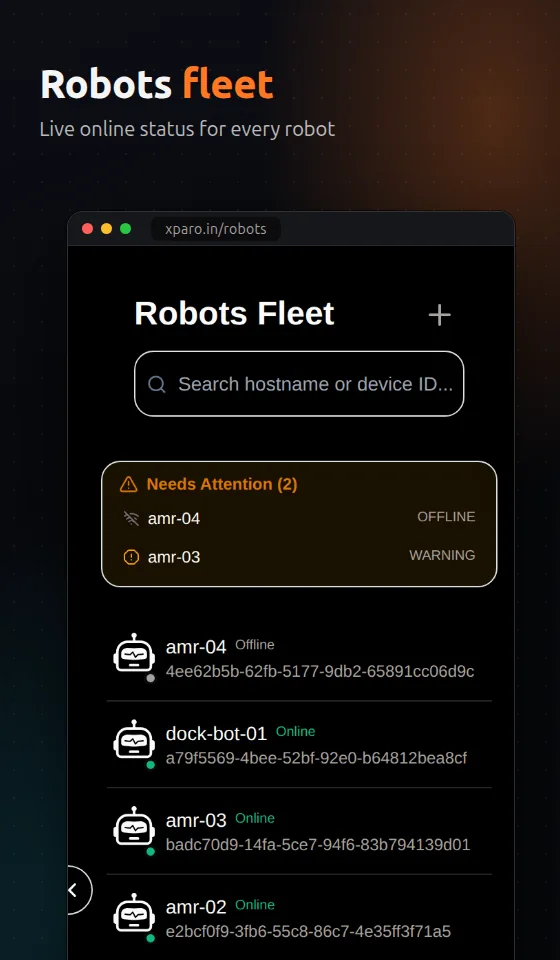
Fleet dashboard
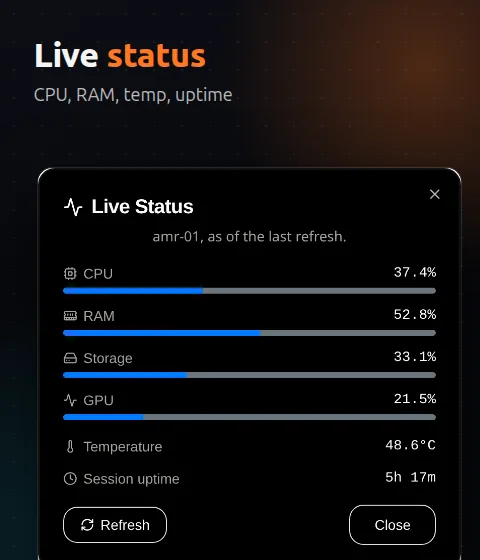
See every robot's online status, telemetry and reachability live, in one dashboard shared with your team.
Behaviour tree editor
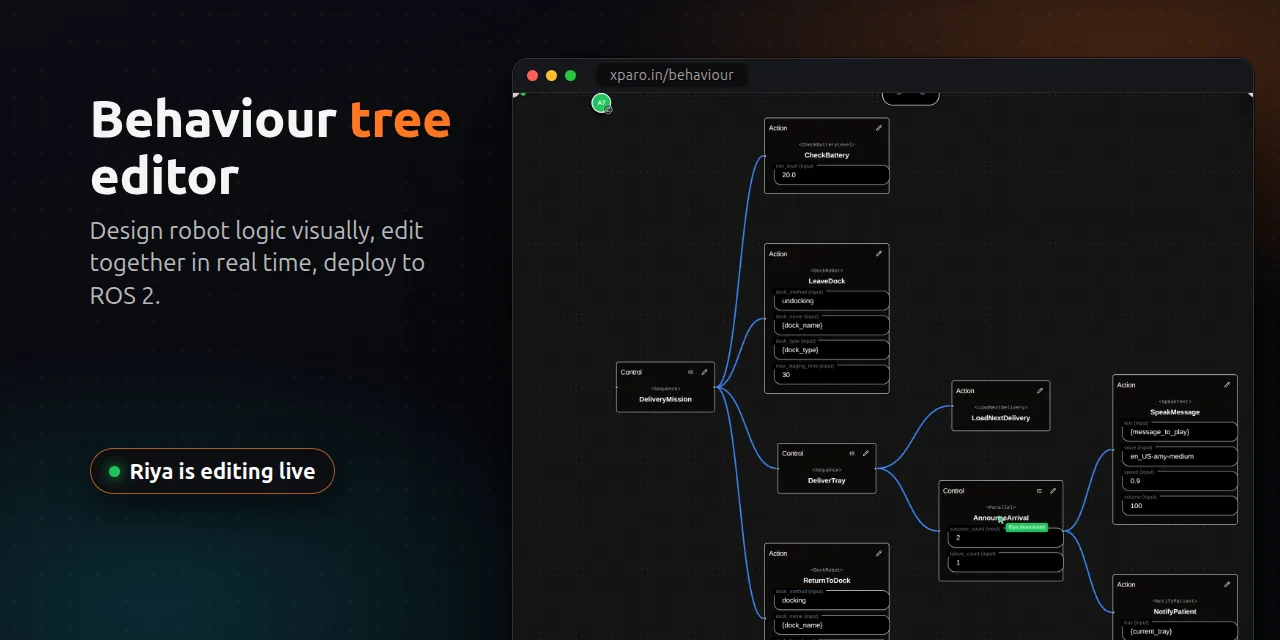
Design robot logic visually. Edits sync live between teammates, and the AI assistant can change trees from plain English.
Tasks
Turn a behaviour tree into a task, map its parameters, and dispatch it to one robot or across your whole fleet.
Remote operations
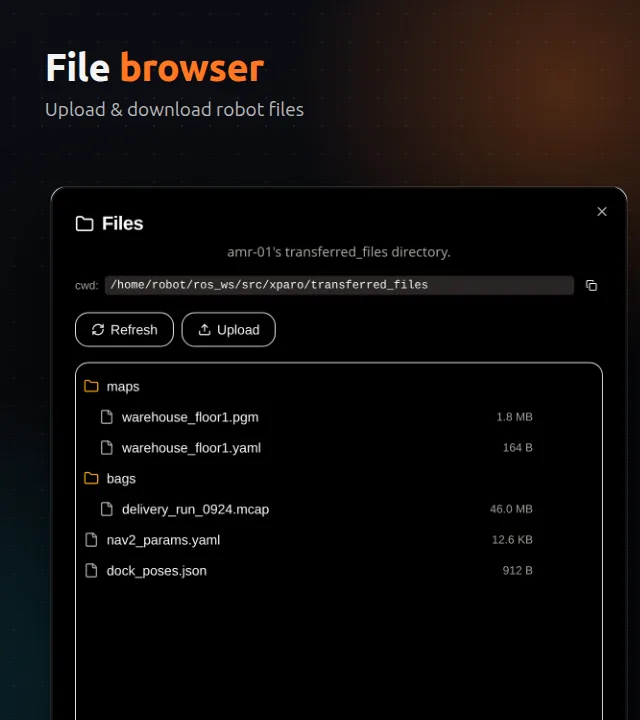
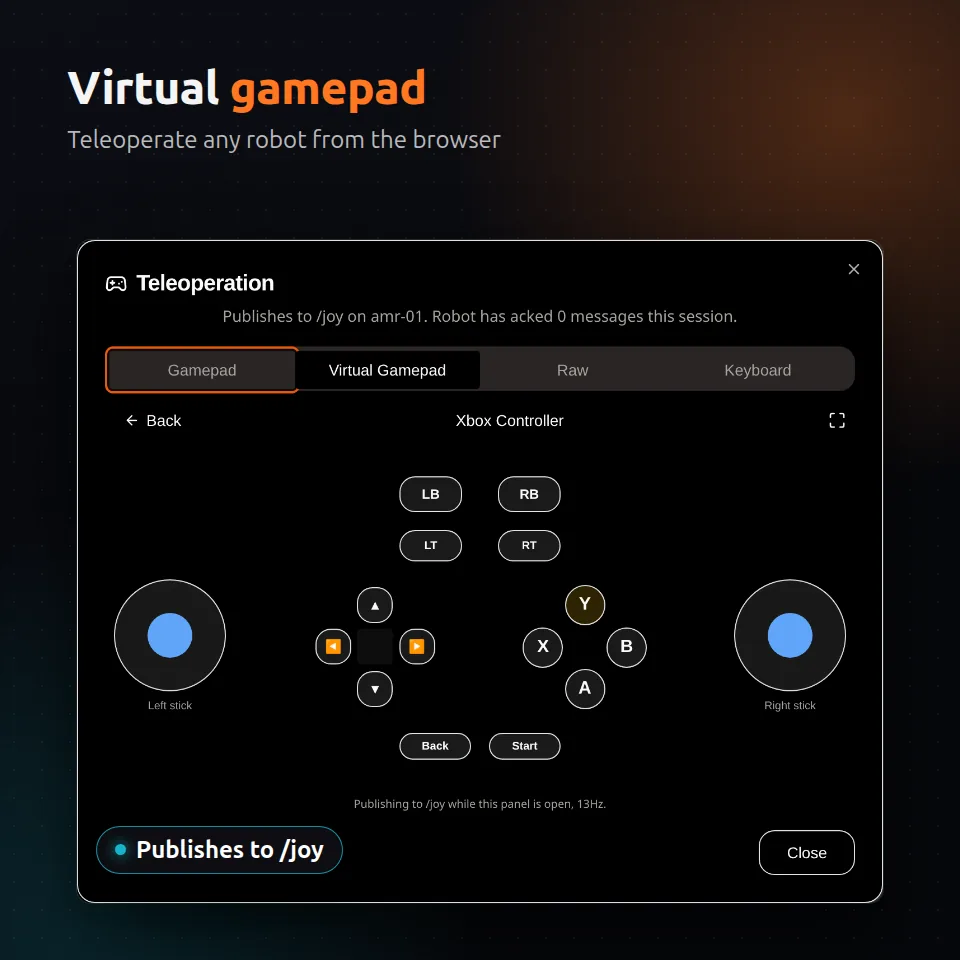
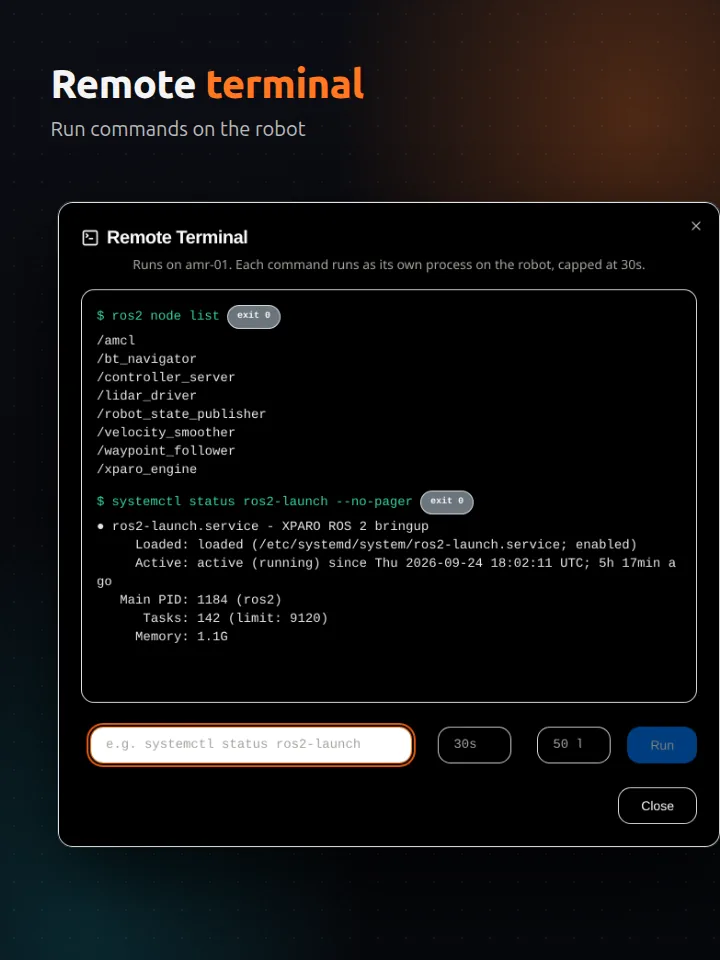
Drive with a virtual gamepad or keyboard, open a terminal, and browse or transfer files on any connected robot.
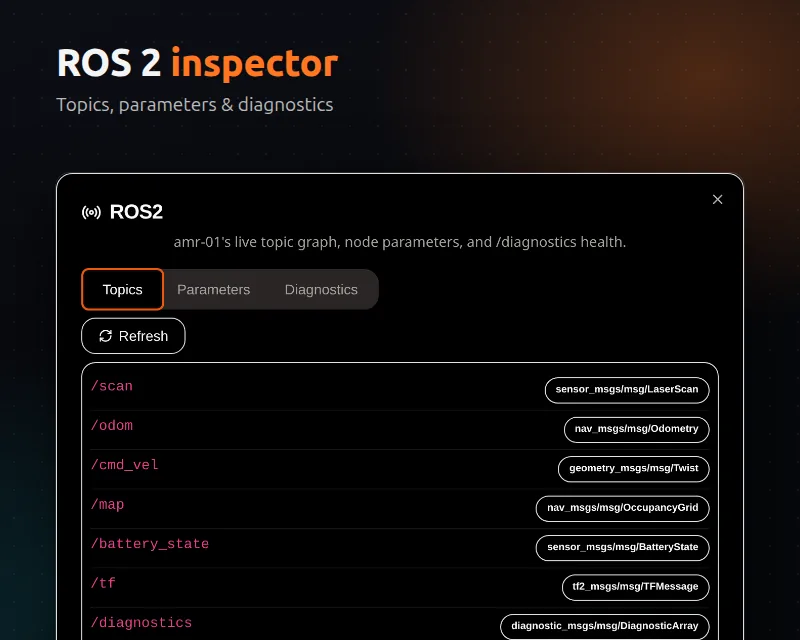
ROS 2 native
Add the xparo package to your workspace, set your project key and launch. Connect through the cloud, a local server or a tether.
Rosbags & data
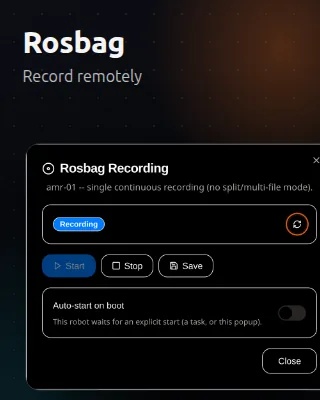
Start and stop rosbag recording remotely and upload bags to cloud storage. Logs, sensor data and reports stay organised per project.
How it works
From sign-up to a robot running tasks, in five steps.
Sign up free and create a project in the dashboard. Invite teammates with the right roles and grab your project key.


Growing every day
Live numbers from XPARO right now.
12
Robot projects built
3
Builders on XPARO
52
Blog posts published
Free to start: unlimited projects and robot fleets, behaviour trees with live monitoring, and 5 MB of storage. Need more? Pay-as-you-grow credits. See pricing
A look inside XPARO
Ready to put XPARO on your robot?
Create a free project, add the xparo package to your ROS 2 workspace with your project key, and watch your robot come online in the dashboard.
About me
PJ
Developer and Founder
Pankaj Jangir
Hi, I'm Pankaj Jangir. XPARO is my dream project: a platform that helps you build and run robots, so you can achieve your DREAMS.
If you have any query or issue, feel free to contact us.
Email: [email protected]
Contact