Search projects and blogs.
Confused, how to use xparo or what this tool is? Here's the documentation to help you manage fleets, analytics database, and edit the core behaviour tree in real time.
read Docs now..See and check BehaviorTree.CPP XML in your browser, no Groot install needed.
Kinematics and odometry for two-wheeled robots, worked out for you.
Pick drive motors with real numbers: torque, speed and power per wheel.
Convert orientations the way ROS does, and stop guessing axis orders.
A serial monitor and plotter that runs in your browser, no IDE needed.
Learn PID tuning by feel on simulated motors before touching real hardware.
Clean up SLAM maps for Nav2 without installing GIMP or writing scripts.
Ready-to-build ROS 2 packages in seconds, for Python and C++.
Ohm's law, dividers, resistor and capacitor codes for robot builders.
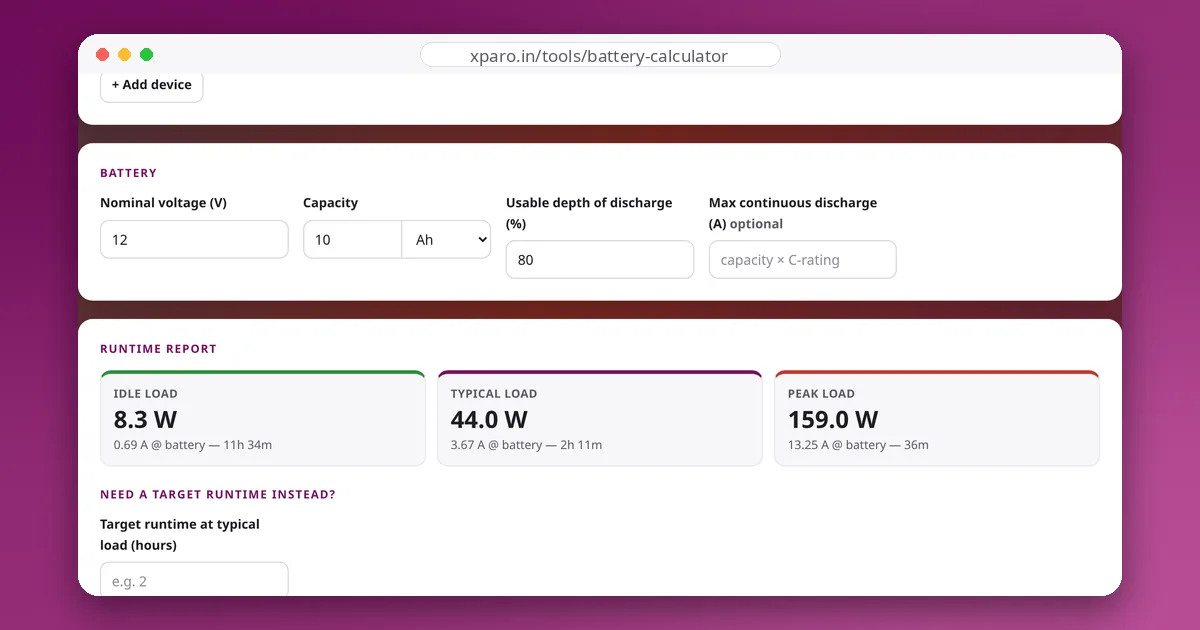
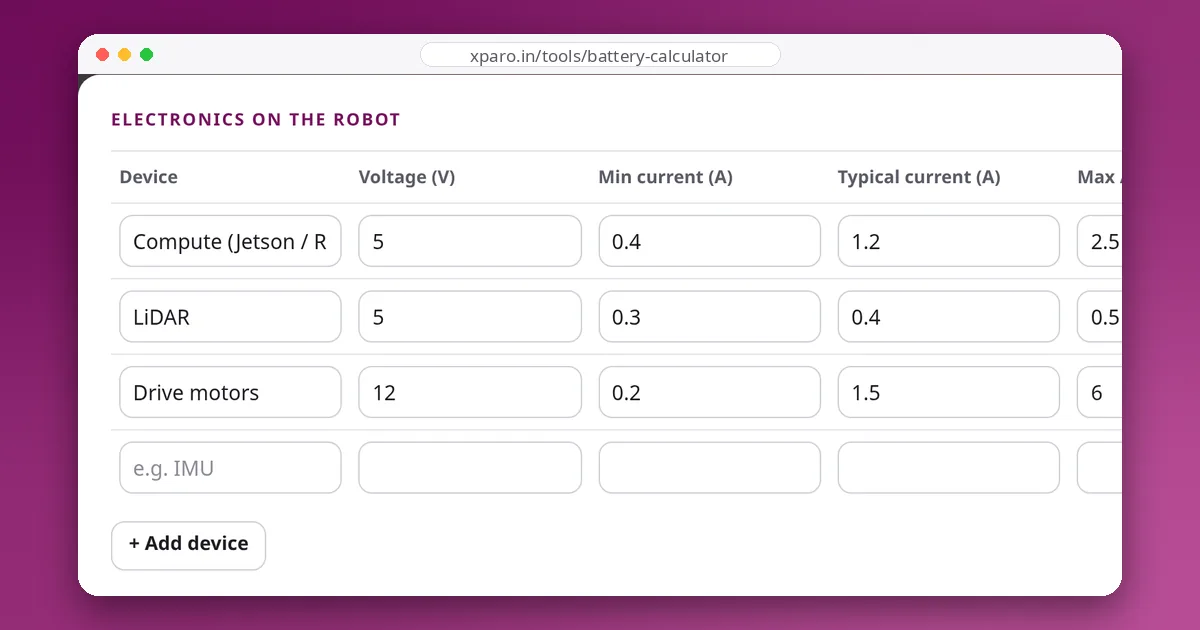
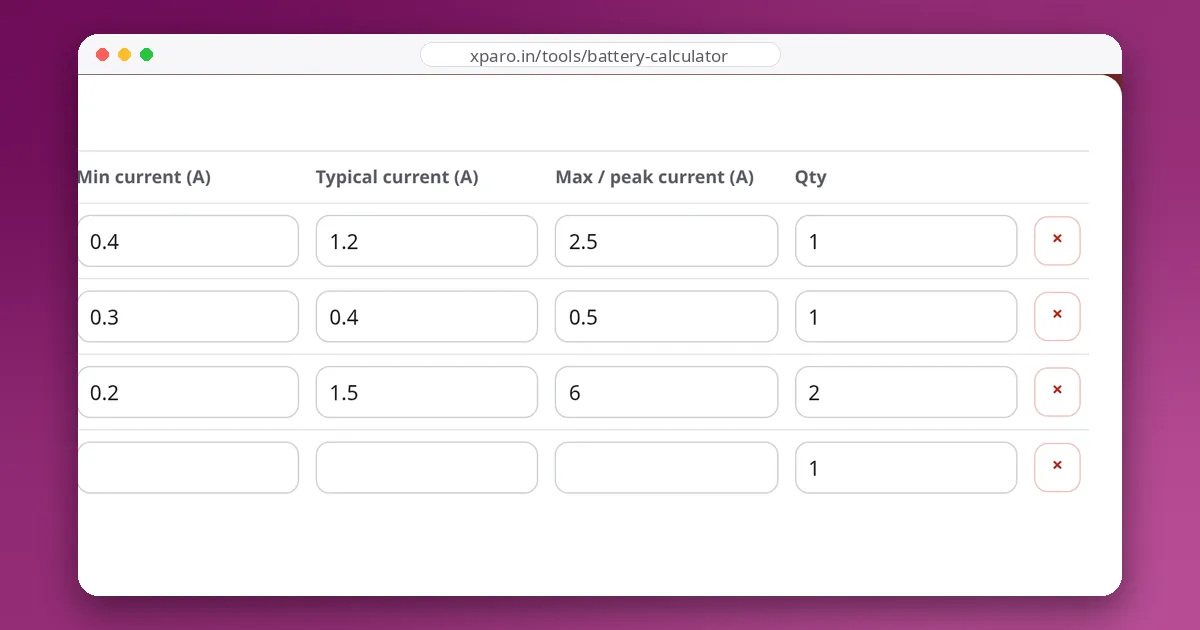
Estimate how long a robot runs on one charge, before you buy the battery.